Ayaan Choudhury

Final Year Mechanical Engineering @ IIT Jodhpur

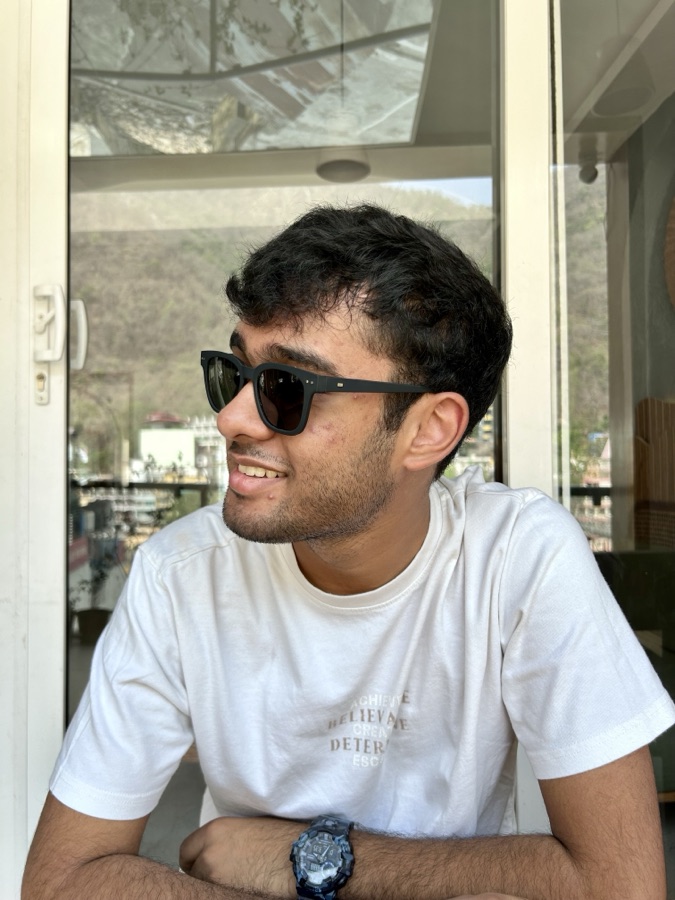
Portrait of Ayaan Choudhury

Hello! I'm Ayaan Choudhury, a final year Mechanical Engineering student with an Interdisciplinary Specialization in Robotics and Mobility Systems at the Indian Institute of Technology Jodhpur. I'm broadly interested in 3D vision and robot autonomy, with my current focus on dexterous manipulation using reinforcement learning and vision-language-action grounding, and LiDAR-based localization and volumetric mapping for autonomous navigation.

Currently, for my B.Tech project, I work at the Robotics Lab, Department of Mechanical Engineering, IIT Jodhpur, advised by Prof. Suril Shah, where I am developing a 7-DOF tendon-driven robotic hand for dexterous manipulation including mechanical design, reinforcement-learning-based control, and sim-to-real transfer, along with VLA grounding for language-conditioned pick-and-place, where the hand grasps and places objects specified through natural-language instructions.

I also work with 3DVisLab (now at IIT Bombay), supervised by Dr. Avinash Sharma, where I work on developing learning-based LiDAR localization frameworks for robust autonomous navigation in sparse outdoor environments. This (2026) summer, I was a research intern at BotLab Dynamics, supervised by Dr. Lokender Tiwari, where I built real-time volumetric occupancy mapping and incremental ESDF construction from TSDFs for UAV navigation in previously unmapped indoor environments, and deployed a ROS 2-based autonomy pipeline for live collision-free flight.

Beyond academics, I've been playing the drums since I was nine, trained at the Trinity Rock & Pop School (Grade 6), and have performed at more events than I can count through school and undergrad, including Inter IIT Cult Meet 6.0, 7.0, and 8.0. Musically, I'm hooked on Indian rock bands like Pineapple Express (jazbaat!), The Local Train & Anand Bhaskar Collection (seriously, give them a listen, you'll thank me later), alongside the classic 70s-80s canon: the Beatles, Pink Floyd, and everyone of that era..

Publications

MB-Loc: Multi-planar Bird's-eye-view Localization in outdoor LiDAR scenes
Ayaan Choudhury, Preet Savalia, Anirudh Pydah, Avinash Sharma
TL;DR: MB-Loc projects LiDAR scans into a multi-planar bird's-eye-view representation and regresses scene coordinates for real-time, viewpoint-robust global localization, outperforming prior 3D scene-coordinate-regression methods in both accuracy and efficiency.
SHIFT: Surface-aware High-speed Integration For TSDFs
Ayaan Choudhury, Lokender Tiwari
TL;DR: SHIFT speeds up real-time TSDF/ESDF mapping by compressing flat, redundant surface regions into super-rays and freezing converged voxel gradients, cutting integration cost by up to 4× while keeping mesh error within millimeters.

Experience

Research Experience

Robotics Lab, Department of Mechanical Engineering, IIT Jodhpur

Undergraduate Researcher · Supervisor: Prof. Suril Shah

Developing a 7-DOF tendon-driven robotic hand for dexterous manipulation, integrating mechanical design, reinforcement learning-based control, sim-to-real transfer, and Vision-Language-Action (VLA) grounding for language-conditioned manipulation.

3DVisLab, Department of Computer Science and Engineering, IIT Bombay

Undergraduate Researcher · Supervisor: Dr. Avinash Sharma

Developing learning-based LiDAR localization frameworks for robust autonomous navigation in sparse outdoor environments, in collaboration with Qualcomm.

  • Designed a Z-sliced Multi-planar Bird's-Eye-View (BEV) representation that projects 3D LiDAR scans into 15 discretized horizontal planes at 512×512 grid resolution, and built a Scene Coordinate Regression pipeline using a ResNet-based CNN encoder-decoder with a KL-regularized deterministic latent bottleneck and CBAM attention to regress dense 3D world coordinates, with a compact 16M-parameter model that is 6.5× smaller than leading 3D-convolution baselines.
  • Integrated RANSAC-based geometric inference with closed-form SVD (Kabsch) pose recovery to align local LiDAR scans with predicted world coordinates, achieving a state-of-the-art average of 0.91 m translation error and 2.30° rotation error on large-scale outdoor benchmarks, with an optimized end-to-end pipeline running at ~21 ms per frame – a 2.6 to 6.9× speedup over diffusion-based and 3D scene-coordinate-regression baselines.
Department of Mechanical Engineering, IIT Jodhpur

Undergraduate Researcher · Supervisor: Dr. Riby Abraham Boby

Developed an adaptive peg-in-hole robotic assembly framework using multimodal sensing, contact-aware control, and sim-to-real transfer.

  • Integrated real-time spatial feedback from camera streams in MuJoCo to guide manipulator motion, improving approach and alignment accuracy by 15% under varied initial configurations.
  • Processed high-frequency force-torque sensor signals at 1000 Hz to detect contact states, guide insertion behavior during precision assembly tasks, and improve assembly execution efficiency, reducing overall cycle time by 20% under uncertain insertion conditions.

Industrial Experience

BotLab Dynamics

Research Intern · Noida, Uttar Pradesh

Developed autonomous navigation capabilities for unmanned aerial vehicles operating in previously unmapped indoor environments.

  • Built real-time volumetric occupancy mapping from onboard sensor streams and constructed Euclidean Signed Distance Fields (ESDFs) incrementally from Truncated Signed Distance Fields (TSDFs), reducing per-frame TSDF integration latency by ~50% on average relative to state-of-the-art systems (preprint forthcoming).
  • Engineered a ROS 2-based onboard autonomy pipeline integrating mapping, planning, and control, and deployed it on a physical UAV flight computer, validating real-time collision-free trajectory generation through live indoor flights in cluttered, GPS-denied environments.
Kites AI

Computer Vision Intern · Gurgaon, Haryana

  • Developed OCR pipelines using OpenCV, Tesseract, Detectron2, PaddleOCR, and LayoutParser for processing health and medical invoices in collaboration with IIT Delhi and AIIMS, achieving 91.7% extraction accuracy.
  • Enhanced Lipikaar, an OCR library developed by IIT Delhi for indigenous languages, by fixing bugs, improving character recognition accuracy by 20%, and expanding language-processing capabilities.

Teaching Experience

Introduction to Machine Learning (CSL2010), IIT Jodhpur

Teaching Assistant

  • Mentored over 300 sophomore students through weekly laboratory sessions, programming support, and conceptual guidance in core machine learning topics.

Education

Indian Institute of Technology Jodhpur

Bachelor of Technology in Mechanical Engineering with Interdisciplinary Specialization in Robotics and Mobility Systems · CGPA: 8.88

Delhi Public School, Dwarka

High School Diploma · AISSCE: 95.6

Projects

Fast-Planner
Developed a complete ROS 2 port of the Fast-Planner robust flight navigation stack. Authored a comprehensive blog tutorial documenting the architectural migration of real-world robotics stacks from ROS 1 to ROS 2.
SpectraScore
Semantic-perceptual color realism metric and image colorization model.
Dual-Arm Exoskeleton
MATLAB kinematics and simulation for a 14-DOF dual-arm exoskeleton.
Smart Search
Responsive autocomplete with Trie and Suffix Trie data structures.
DemocrEase
Client-server voting system with bar graph visualization.
DSA Implementations
Core data structures and algorithms in C and C++.

Blog

Porting a Real Robotics Stack from ROS1 to ROS2: A Guide
A practical guide to porting a real robotics stack from ROS1 to ROS2, covering the migration process and lessons learned along the way.
Tutorial: How to Spawn a Robot in a Custom Gazebo World using ROS2 Humble
A step-by-step guide to spawning robots in custom Gazebo worlds using ROS 2 Humble, with practical tips and visuals for robotics simulation enthusiasts.
Step-by-step Upgrading Ubuntu 20.04 to 22.04 on a Dual Boot System
A complete walkthrough for safely upgrading Ubuntu on a dual-boot system, with troubleshooting tips and visuals for a smooth transition to Jammy Jellyfish.

Contact

The best way to reach me is by email.